SmolVLA on RTX 5070 Ti and Mac mini: a local inference check
A 50-episode SmolVLA proof of concept on the SO-ARM101, with training notes and synthetic-input latency measurements on an RTX 5070 Ti and a Mac mini.
FIELD NOTES BY ANHOYA
Robot learning, papers read slowly, and the things I figure out by building.
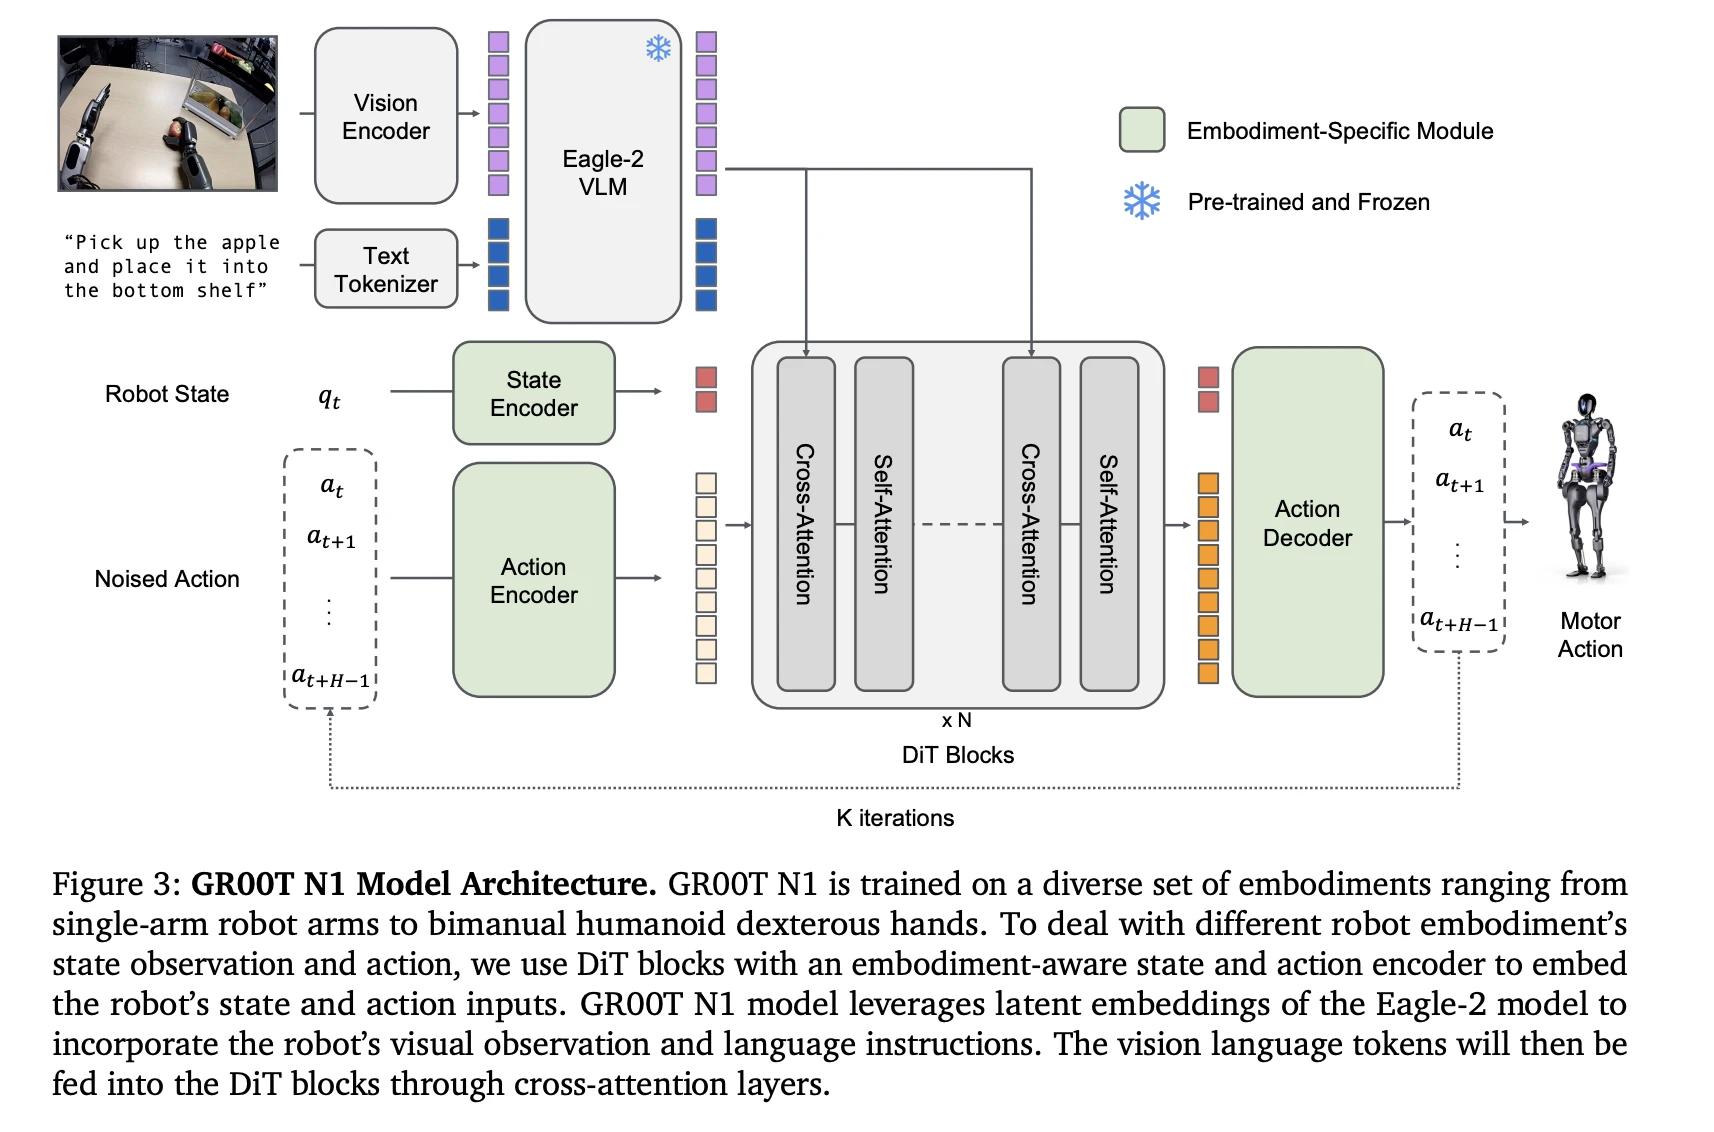
A reading of GR00T N1, from its two-system architecture to the data pipeline that connects different robot embodiments.
A 50-episode SmolVLA proof of concept on the SO-ARM101, with training notes and synthetic-input latency measurements on an RTX 5070 Ti and a Mac mini.
Turn repeated deployment steps into a reusable skill, connect tools through MCP, and decide where your agent must stop for approval. The final part brings all six lessons together.
Keep your project's standing decisions in a rules file, then separate how to build from what to build. Write the direction yourself, even if you dictate it.
Part 5 is about what not to leave to an AI. Three rules for keys and databases, a three-level line for personal data, and then putting your project on the internet, with the logs as your first stop when it fails.
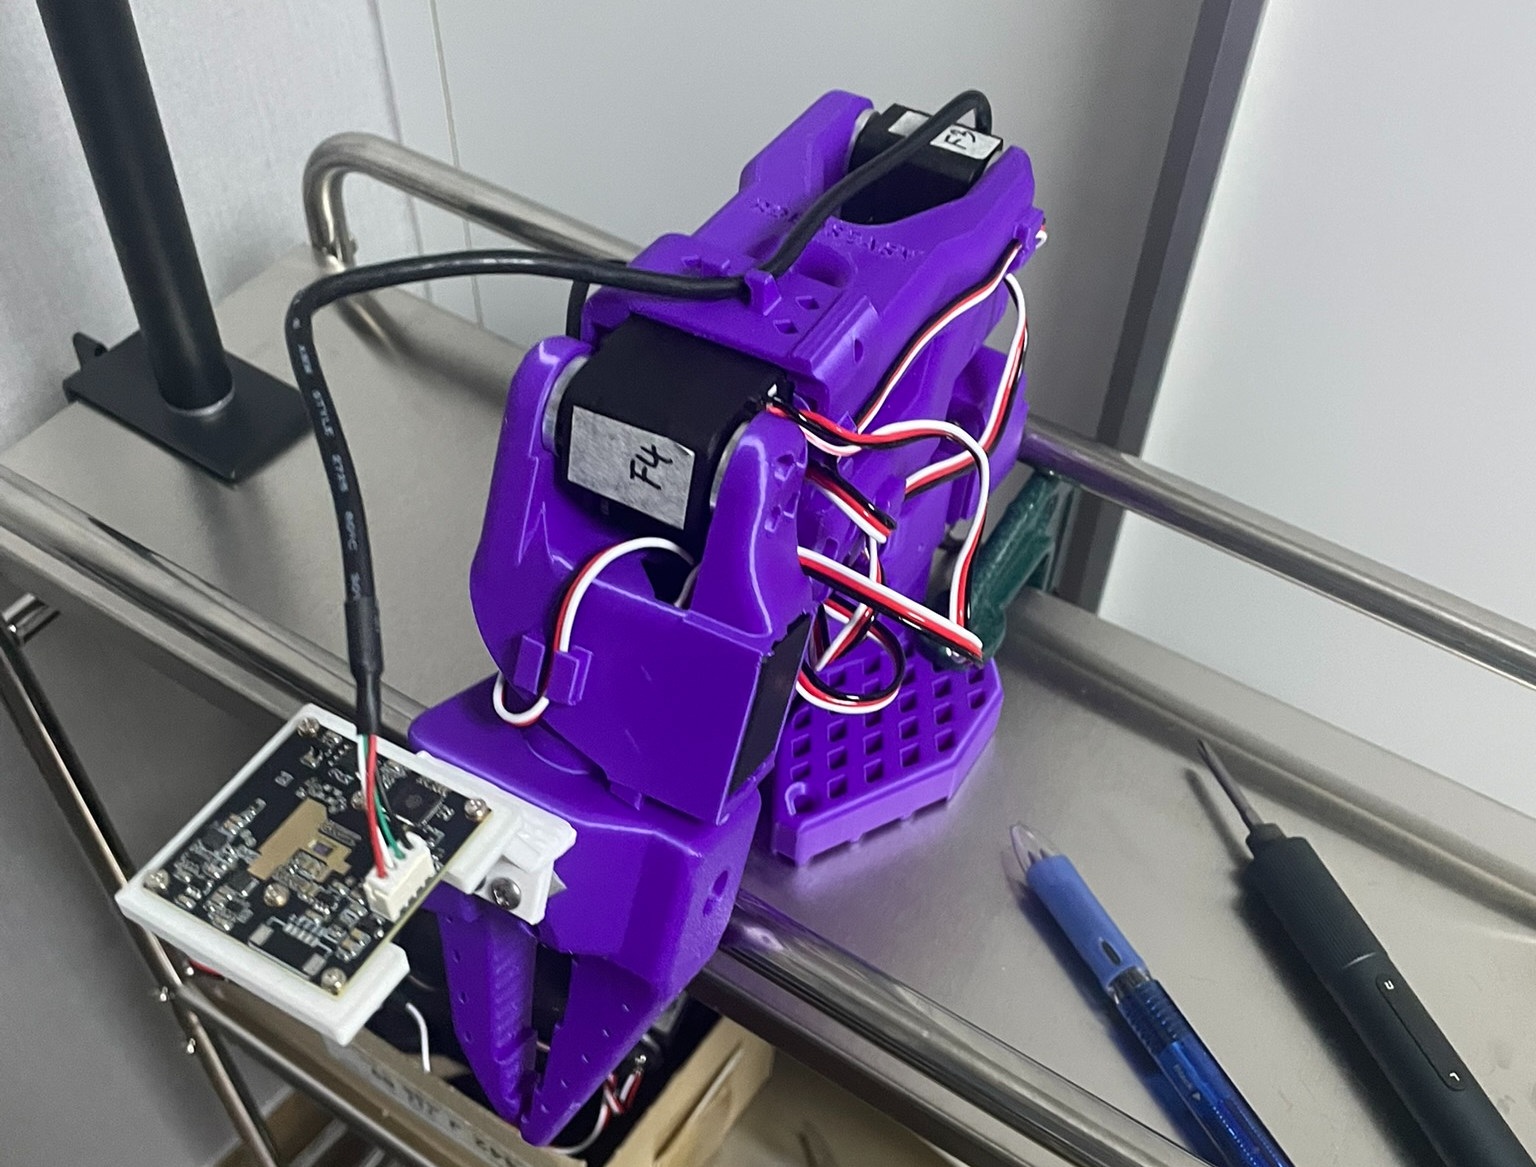
My camera board was too large for the wrist mount I had chosen. A small printed adapter, spare screws, and a layer of double-sided tape solved the fit.
A reading of GR00T N1, from its two-system architecture to the data pipeline that connects different robot embodiments.
The hard part of AI-assisted coding has moved from writing code to checking it. This is the routine I use to keep that checking small: structure the request, review the plan, then test the result myself.
A practical look at inference hardware for ACT, Diffusion Policy, SmolVLA, and larger VLAs, including my own Franka experiment with 80 denoising steps on an RTX 5070 Ti.
Reading Ha and Schmidhuber's World Models: why a VAE and MDN-RNN do most of the work, how an 867-parameter controller learns, and why a harsher dream can transfer better to reality.
AI changes code boldly and sometimes ruthlessly. Part 2 sets up the safety net: commits as save points, rolling back on purpose, short-lived branches, one commit per request, and the difference between Git and GitHub.
AI can write the code, but you still have to direct it, check it, roll it back, and ship it. Part 1 covers the ground the AI works on: paths, hidden files, the terminal, reading Python, errors, and virtual environments.
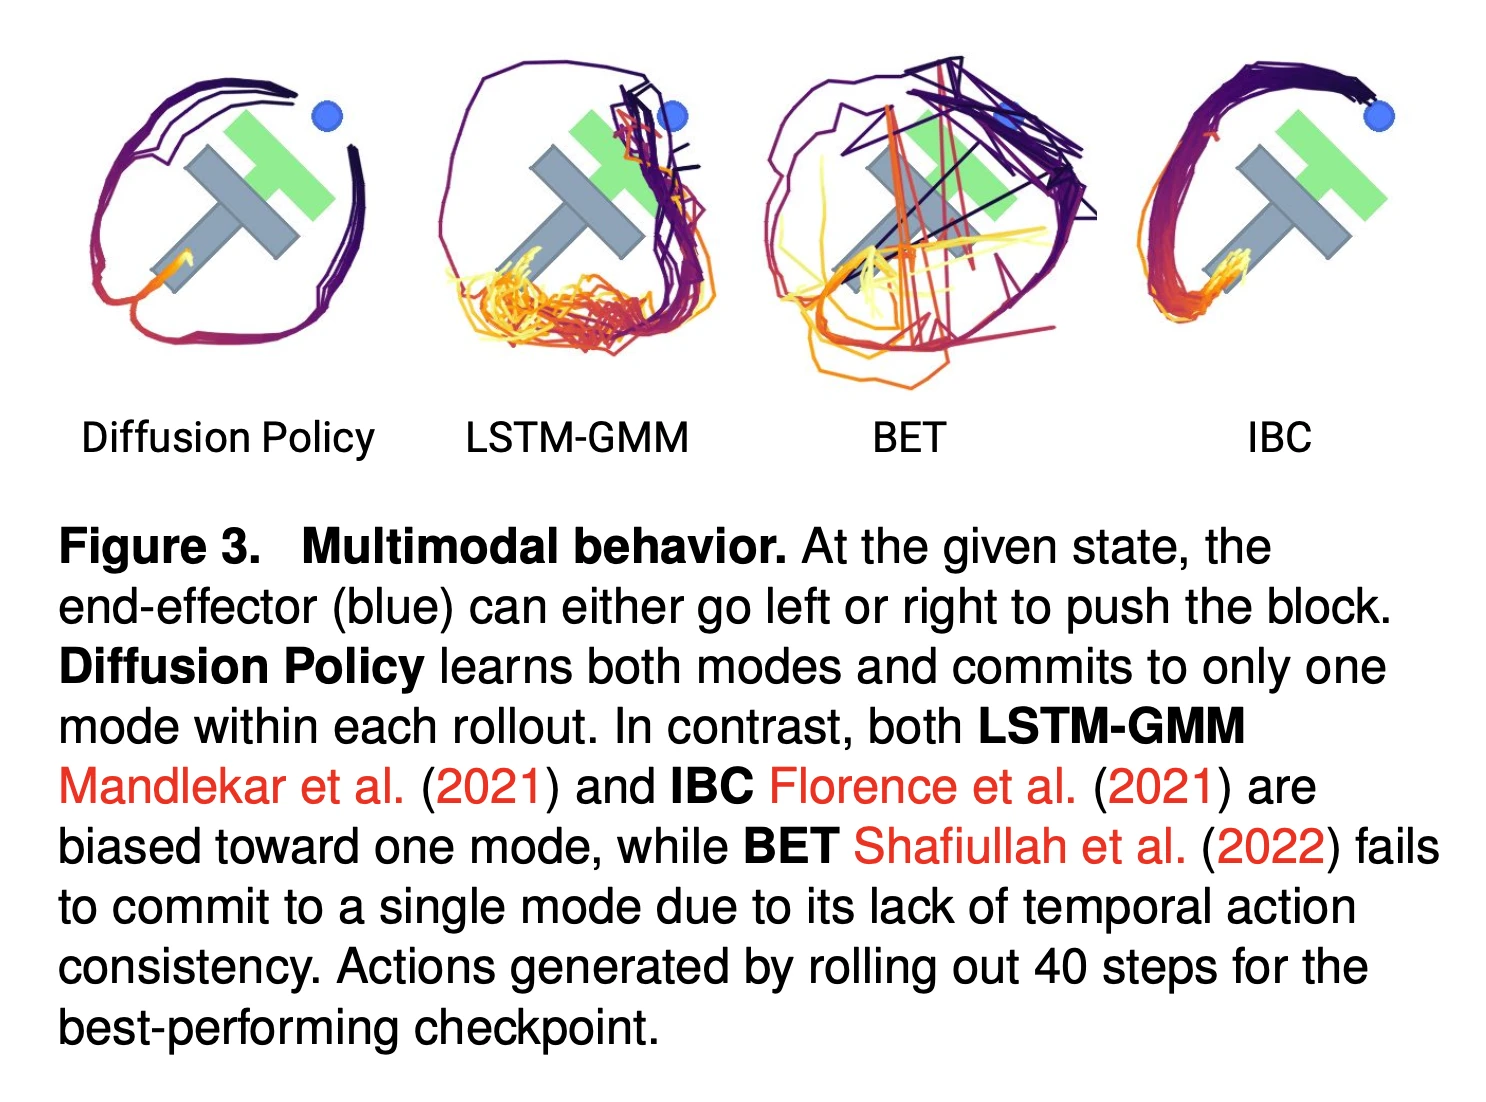
Sections 4 to 9 of Diffusion Policy: modes and basins, why learning the score removes the normalizing constant, the benchmark and real-robot results, and the limits the authors state.
Sections 1 to 3 of Diffusion Policy: why behavior cloning needs multimodal action distributions, how DDPM becomes a visuomotor policy, and the CNN, transformer, and FiLM design choices.
Following Calvin Luo's unified perspective in order: the ELBO, hierarchical VAEs, variational diffusion models, the three equivalent prediction targets, and the score-based view.
A full reading of the original 2013 DQN paper: why deep reinforcement learning was unstable, how experience replay helped, and how to read the Q-learning loss one symbol at a time.
Why an autoencoder isn't enough for generation, how a VAE learns a latent distribution, what each term of the ELBO does, and how the reparameterization trick makes it trainable.
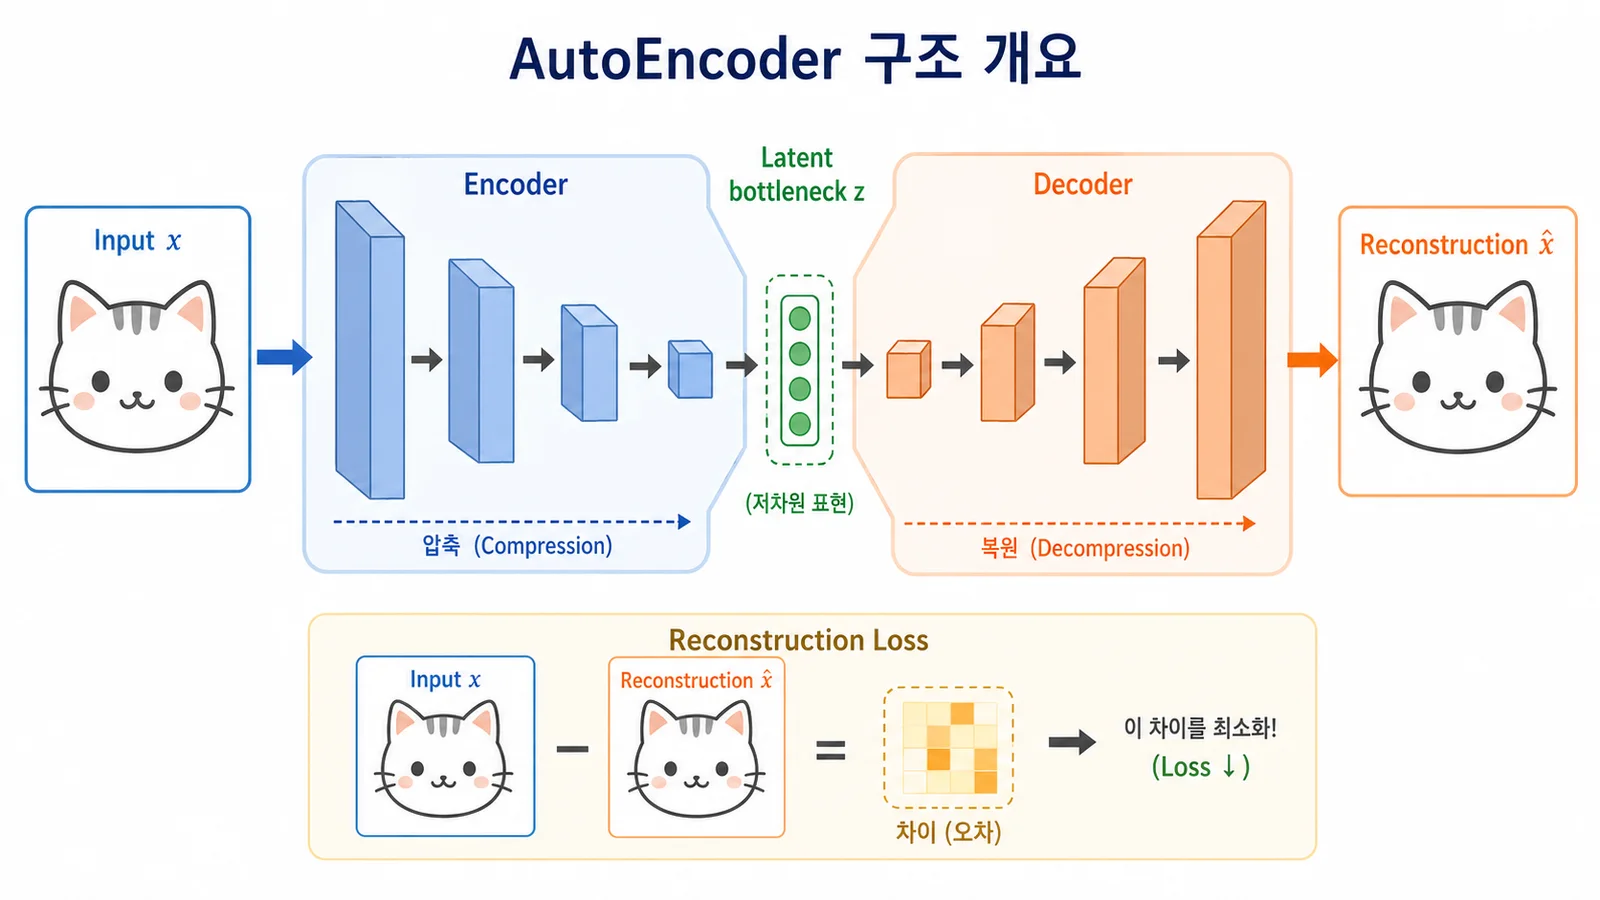
How an autoencoder compresses and reconstructs its input, why the bottleneck matters, what reconstruction loss means in probability terms, and why a plain autoencoder is hard to sample from.
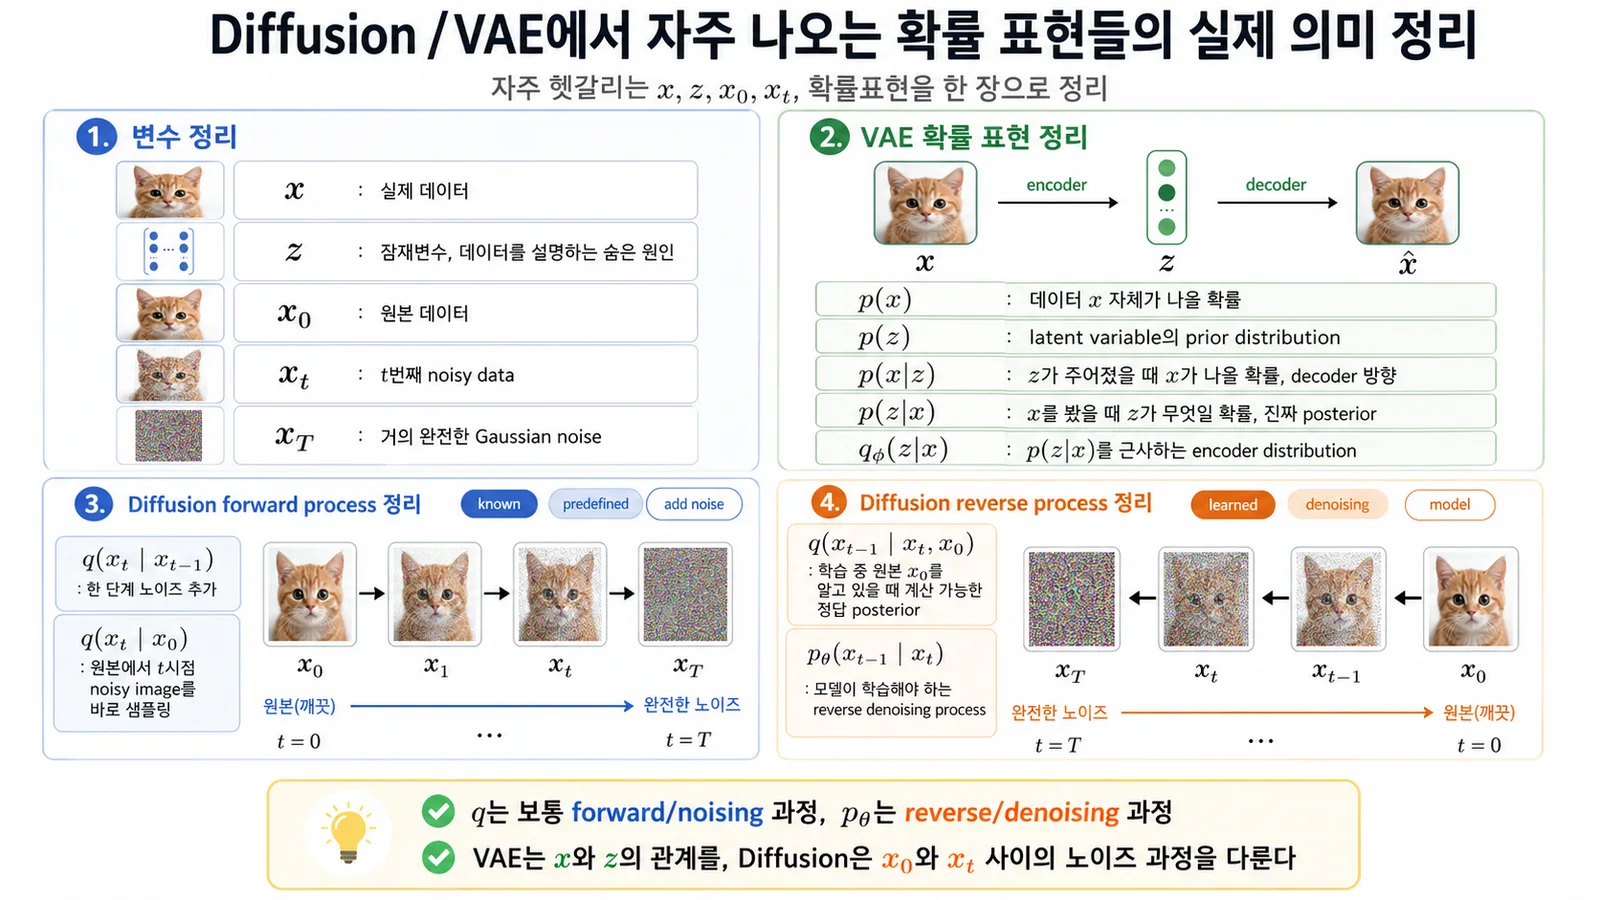
p(x), p(z), p(x|z), p(z|x), q, and p-theta: what each expression in VAEs and diffusion models describes, explained with concrete examples instead of derivations.
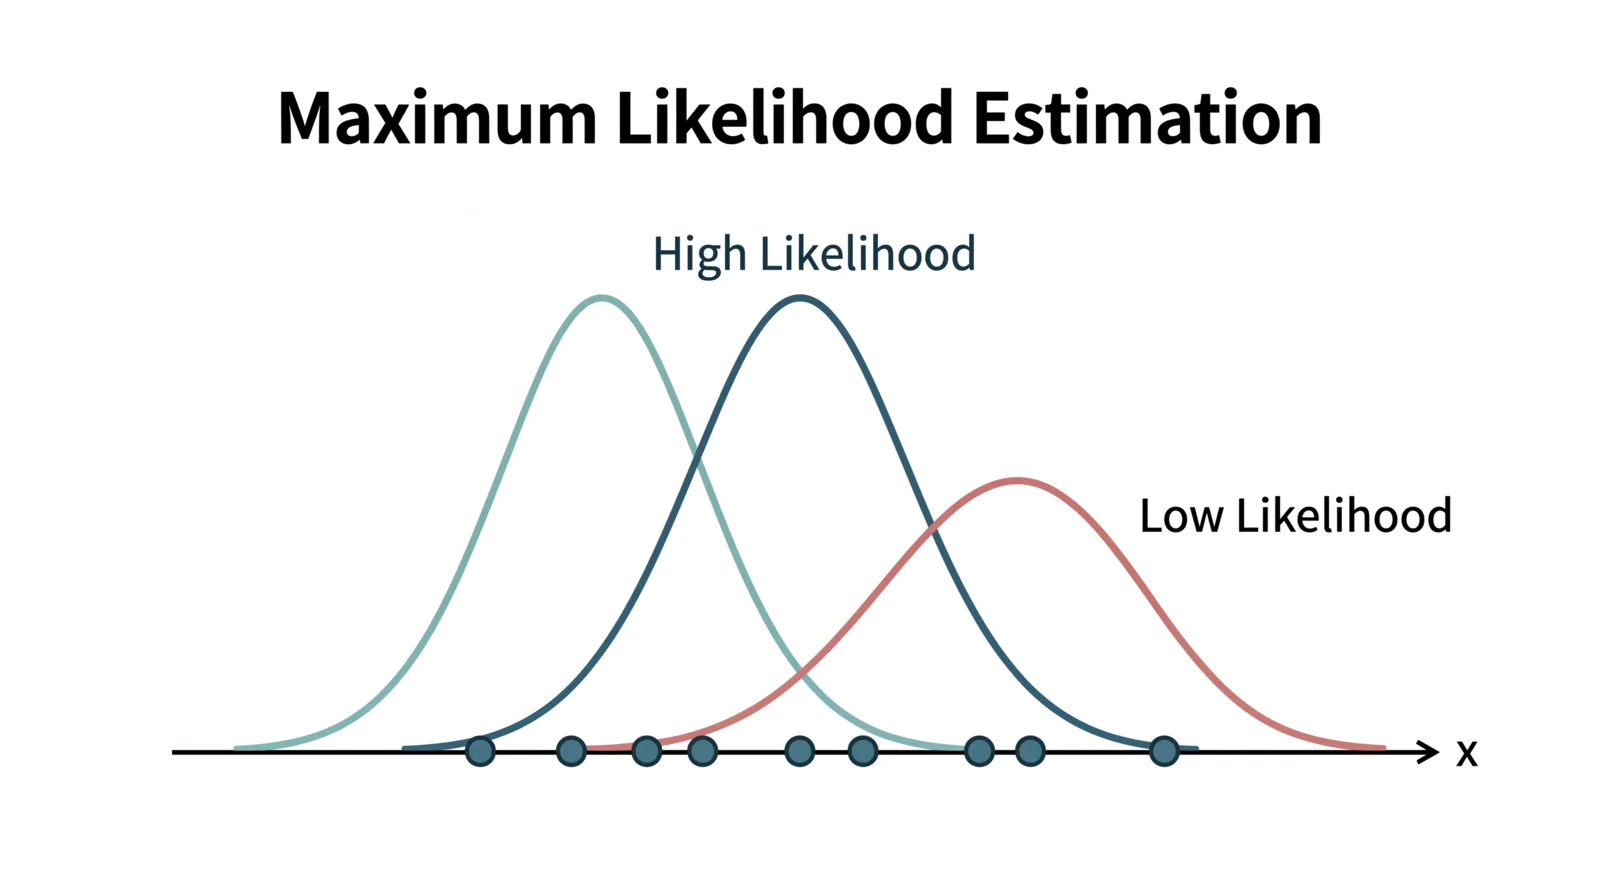
Maximum likelihood explains the losses we use every day: a Gaussian assumption gives MSE, a categorical one gives cross-entropy, and both connect to KL divergence.
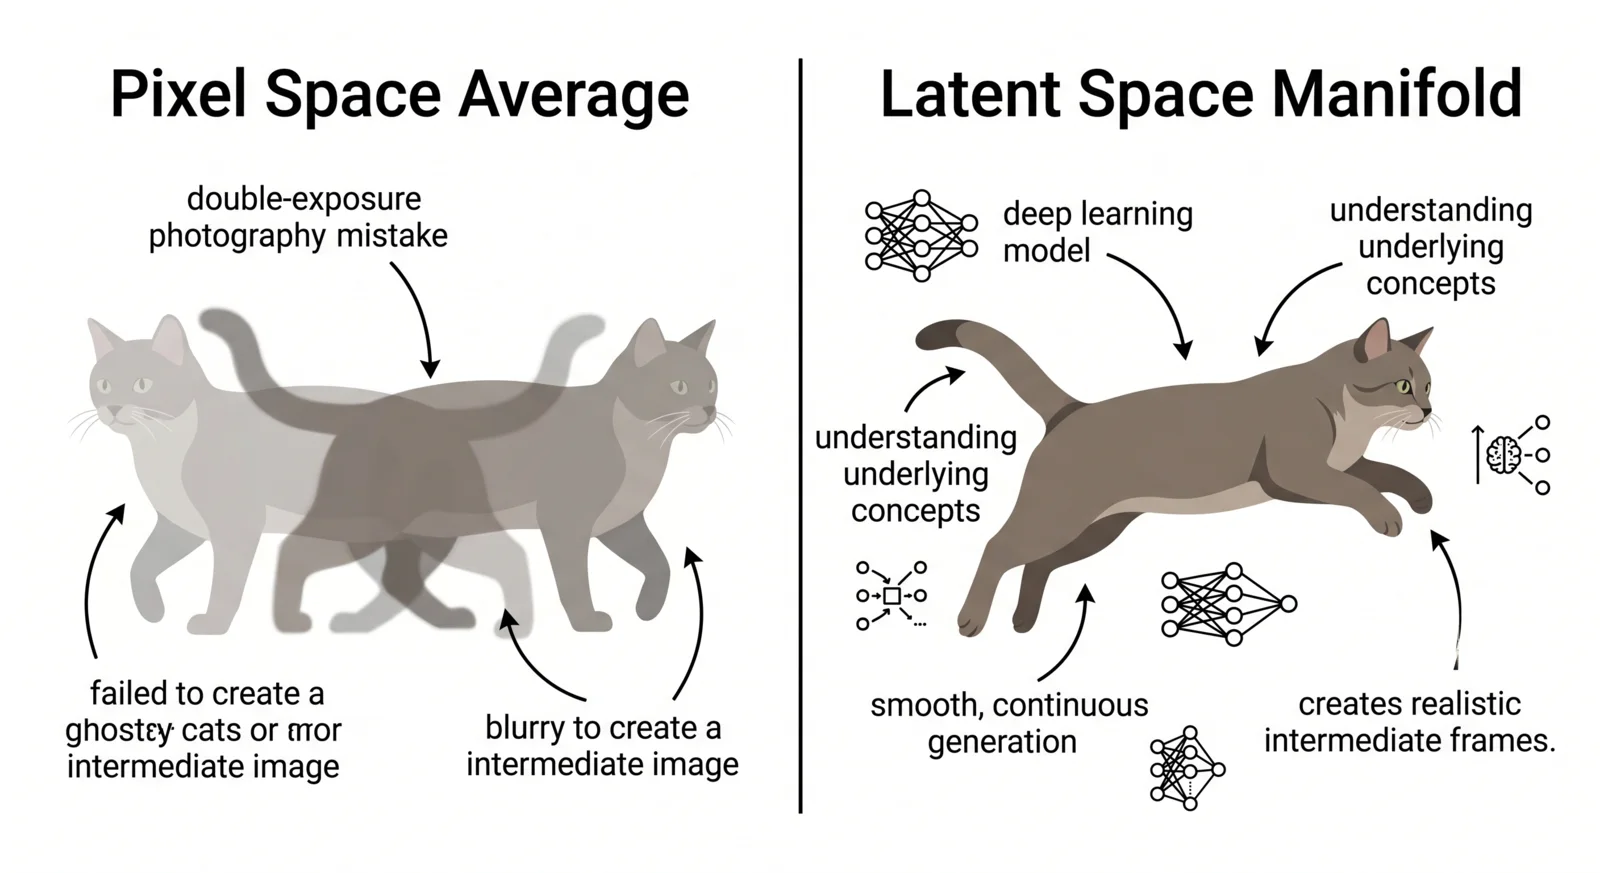
Why a deep-learning series has to start with probability: what distributions, Bayes' theorem, expectation, and Jensen's inequality each contribute to generative models.
Why I started this series as an electrical engineering student with no probability course behind me, how the parts fit together, and the resources that helped most.